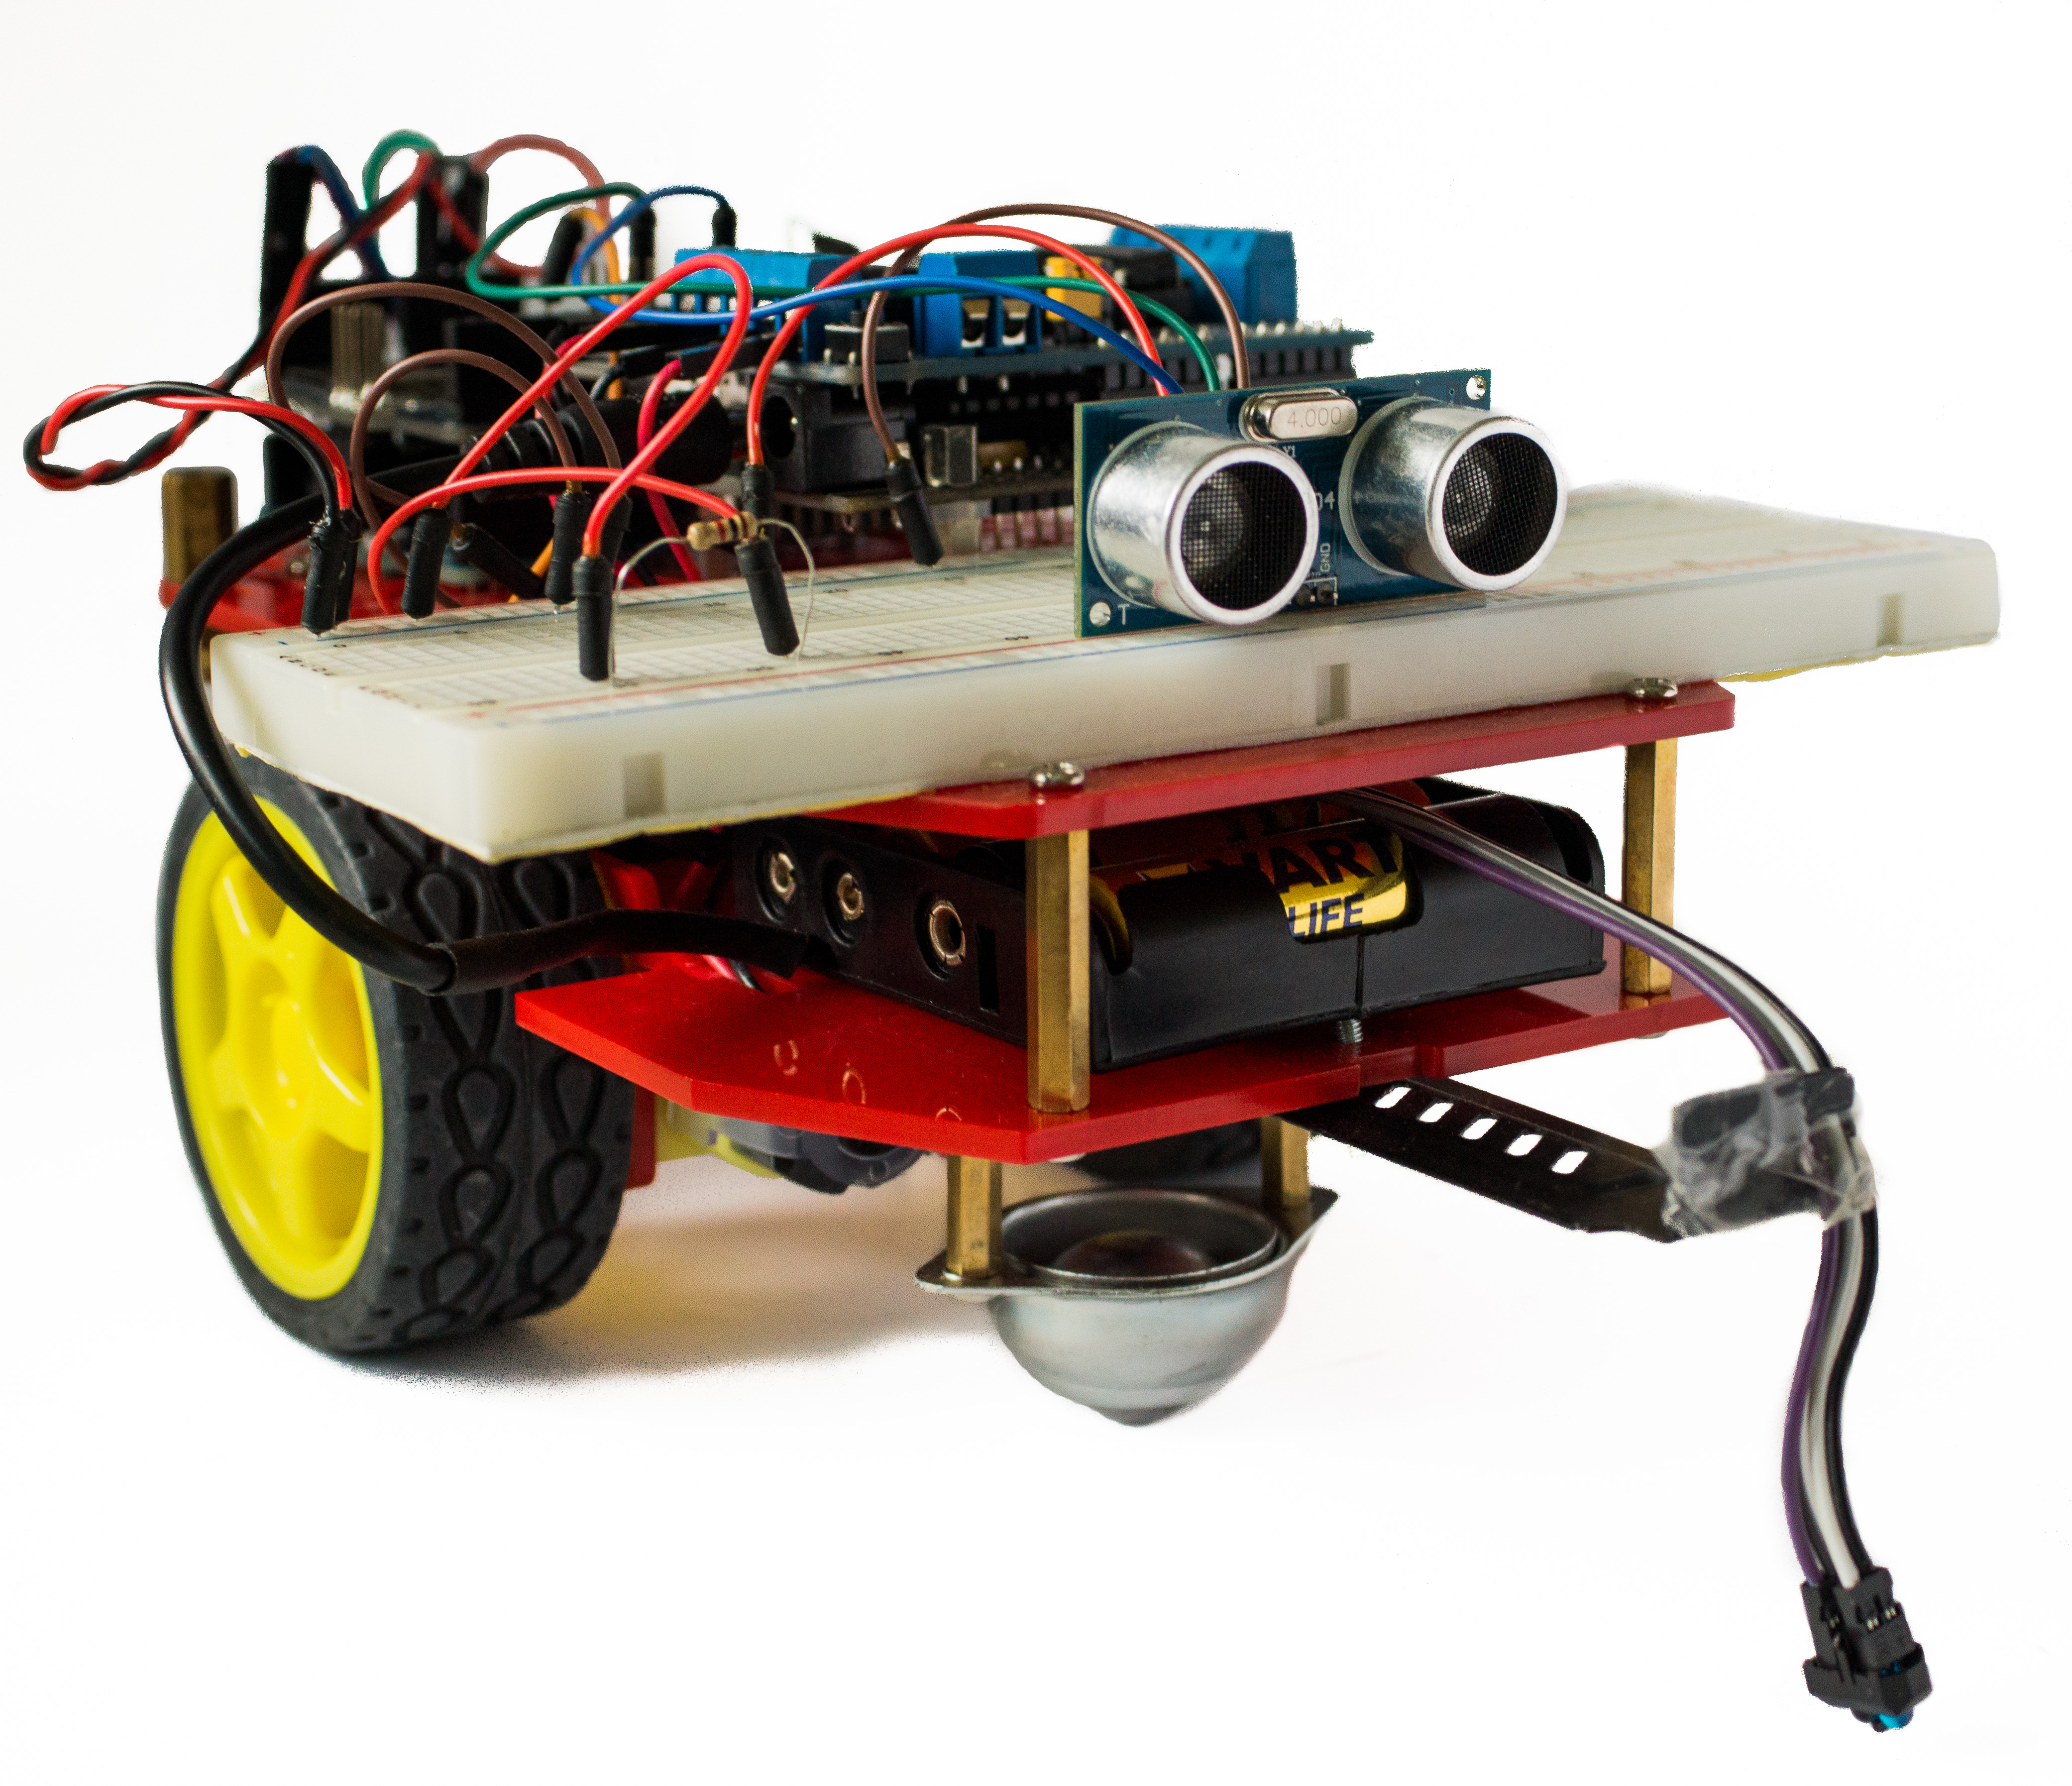
The engineer’s thesis consisted of two parts, the first connected with creation of the robot, the second enabling steerage by the web browser.
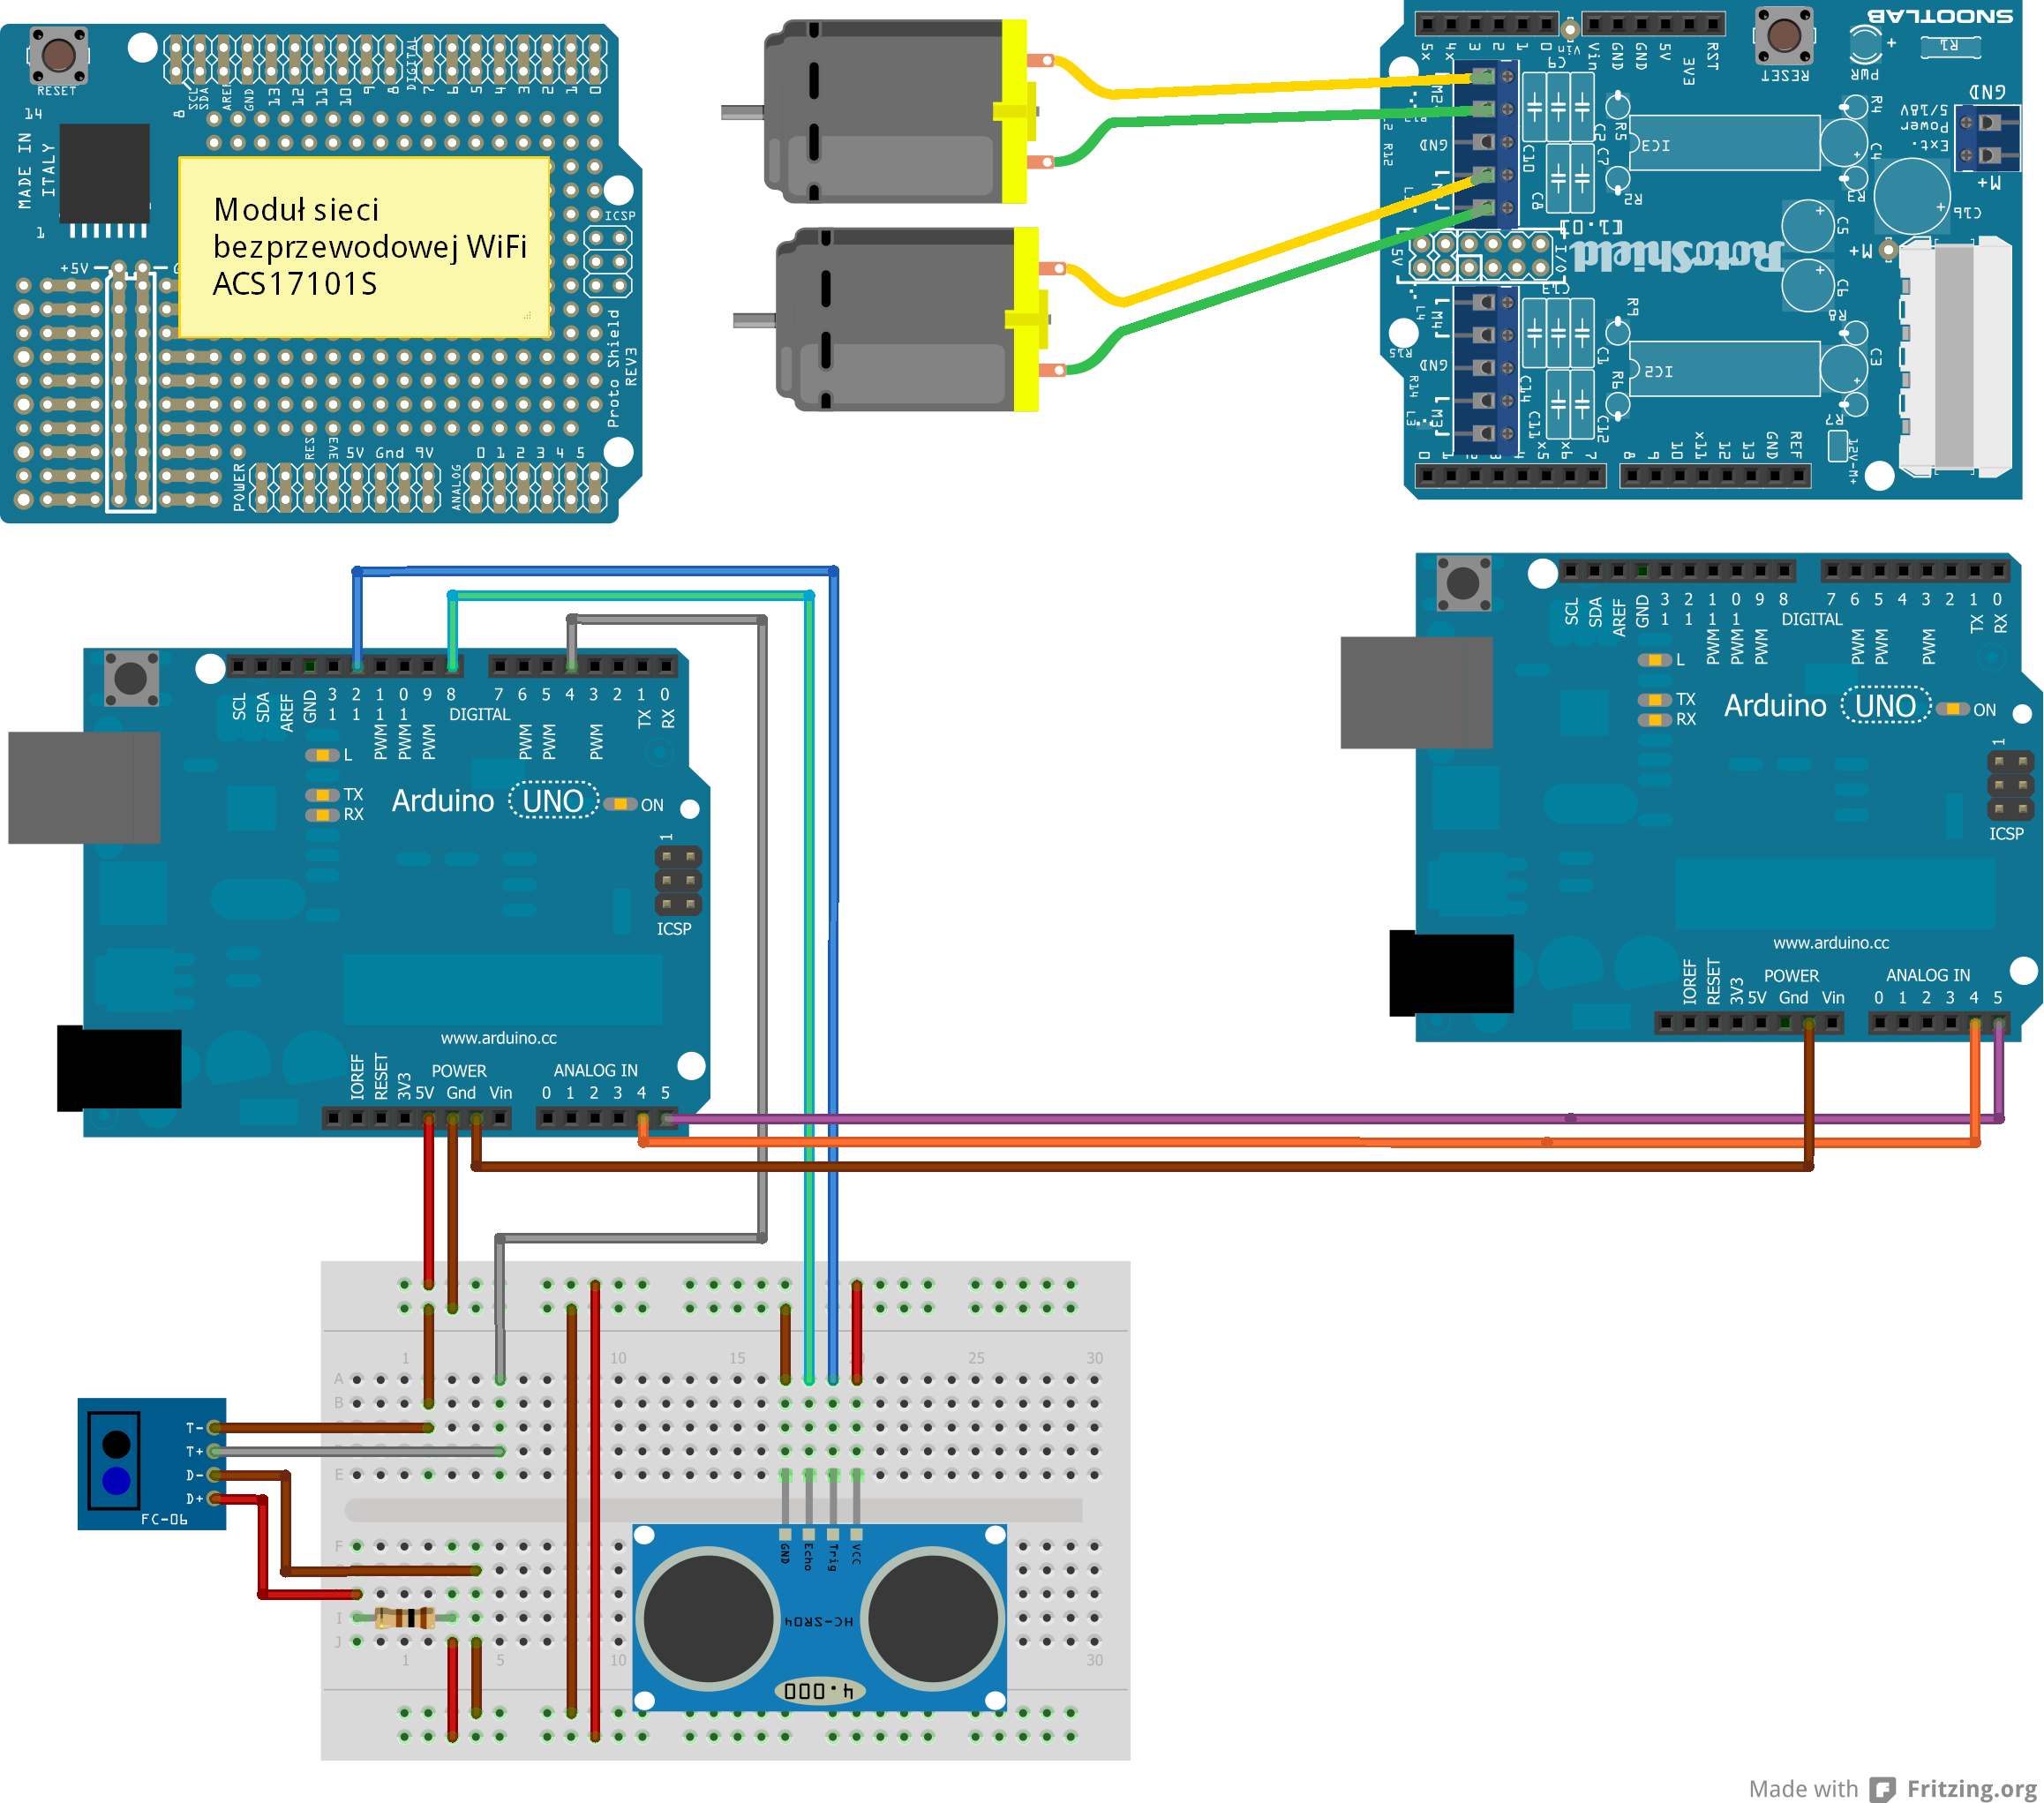
The robot uses Arduino Uno. It has two steering elements, the first is about communication with a server by Wi-Fi network and sending data from build-in sensors – ultrasound and reflective optical sensor. Thanks to these sensors, the robot stops in time to avoid crashing into an obstacle and falling. To eliminate distractions produced by engines, second Arduino Uno steering the robot’s drive was used.
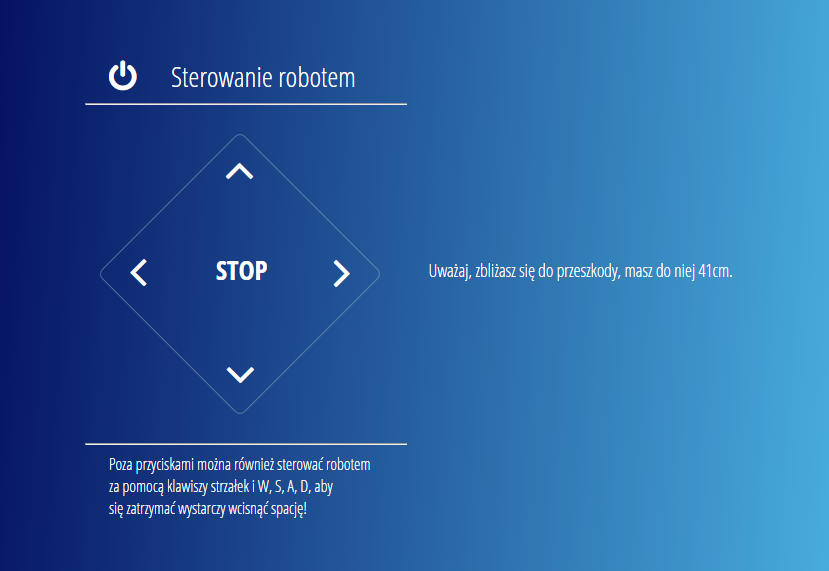
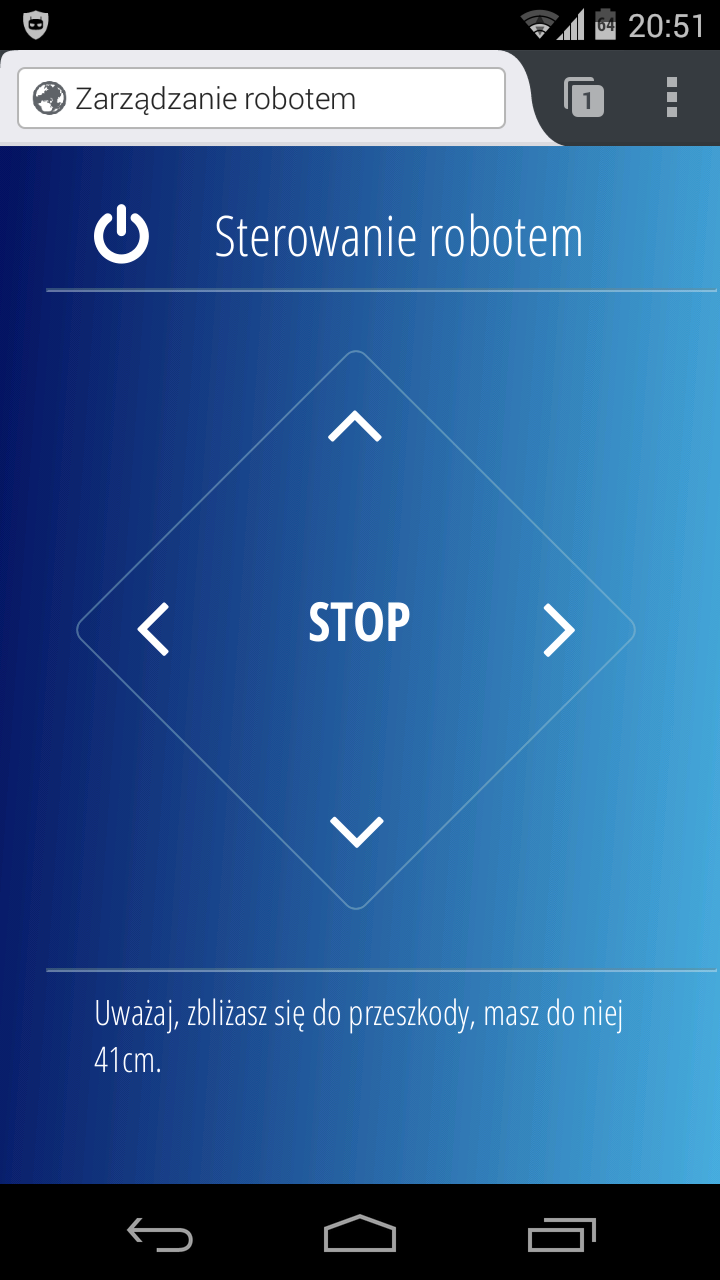
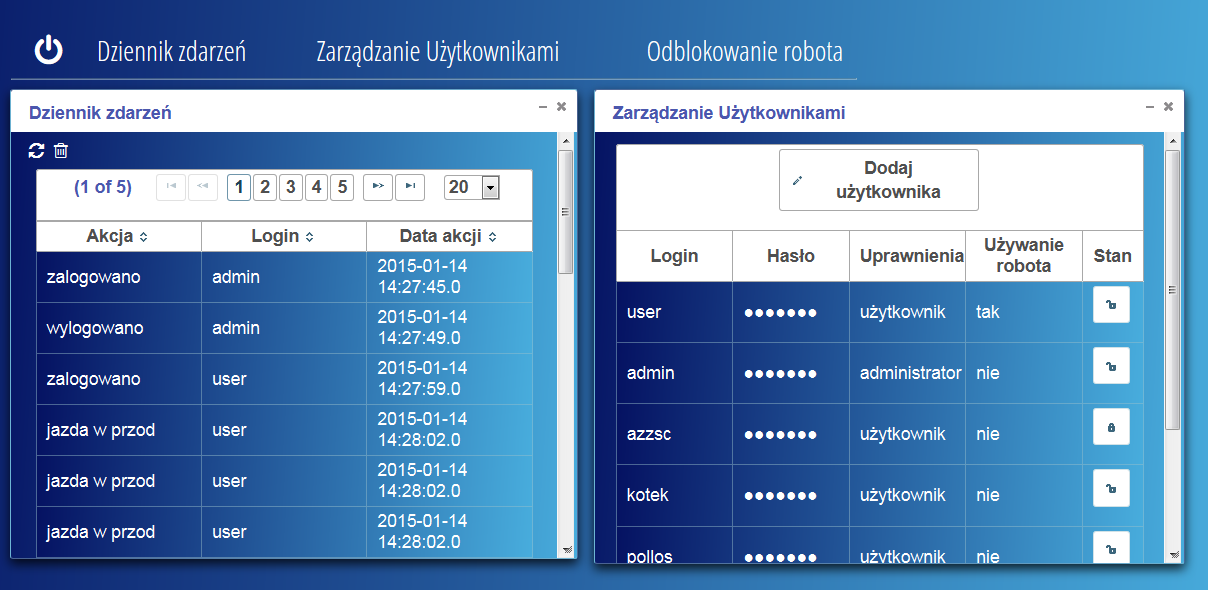
Created web system was divided into two parts. In the first, main part, steerage of the robot was possible by using buttons, either physical or showed on screen. Searching for the robot on the local network starts after logging in to simplify sending and receiving data from build-in sensors. In the second part for the administrator, checking sent commands, users management and log review was possible.
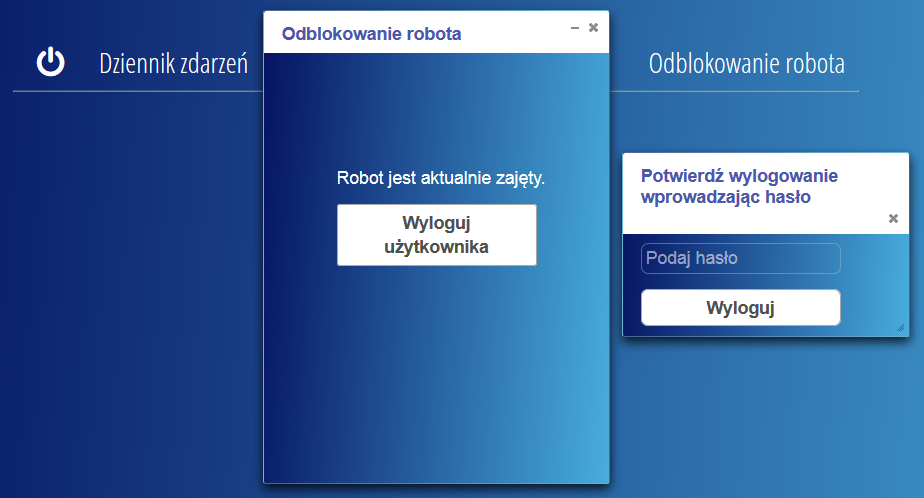
The robot could be steered only by one user at a time, the other one had to wait for his or her turn. If the administrator noticed that, the robot is wrongly steered, it was possible to remotely block its steering panel.