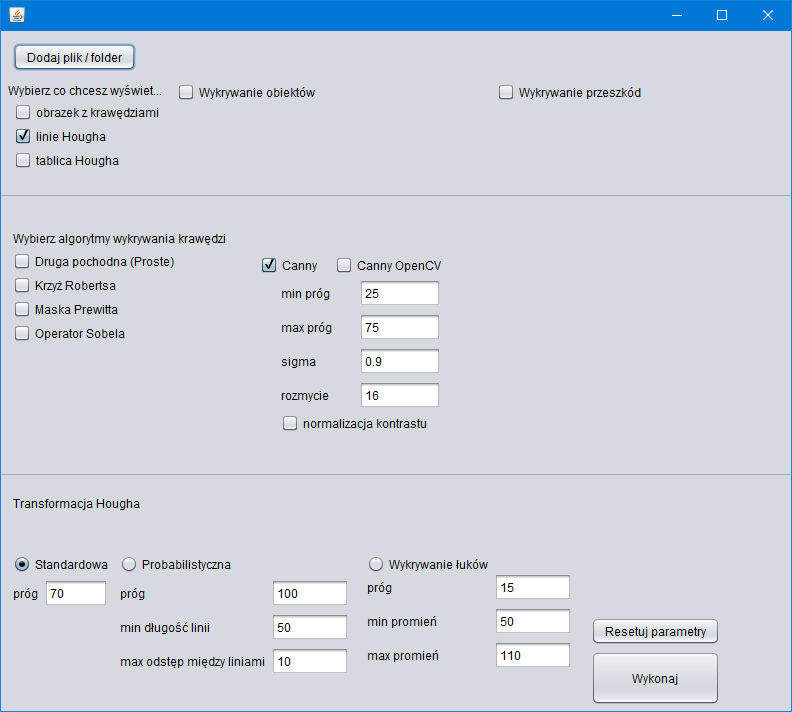
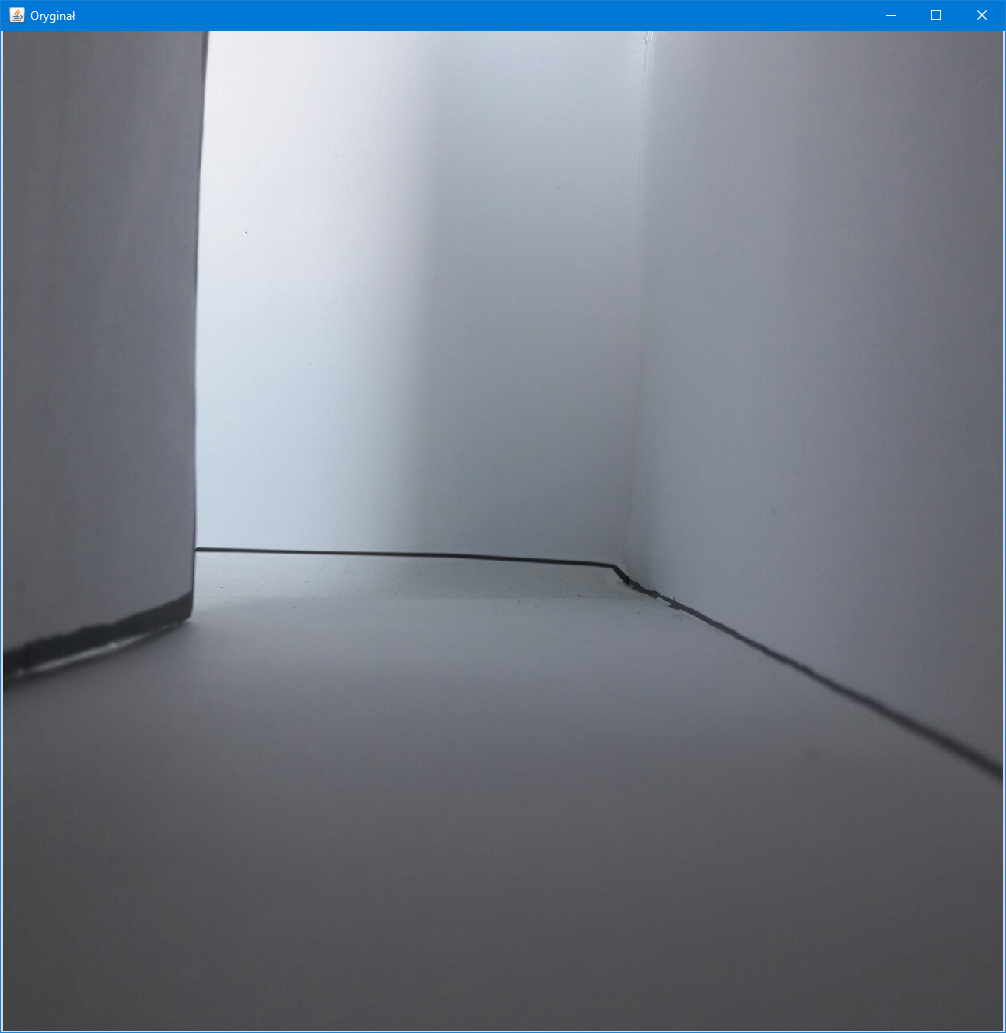
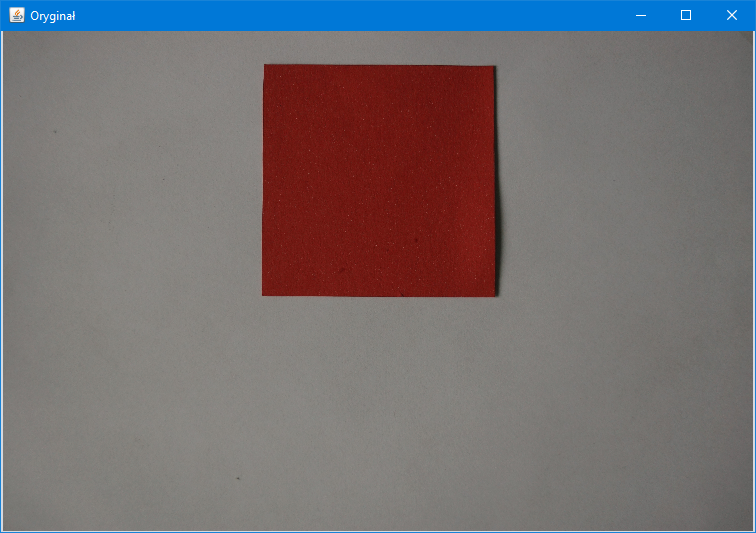
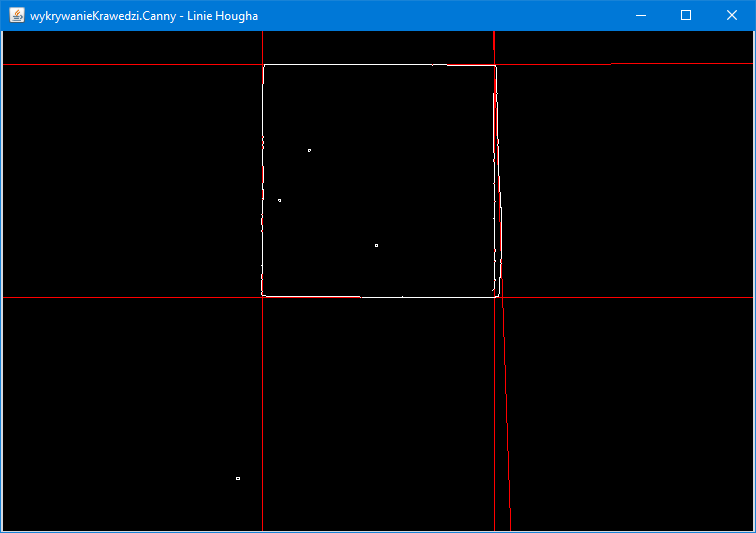
The main task of the master’s thesis was to extend the robot’s functionality (from the engineering thesis) by adding a camera to enable autonomous drive. Pictures taken by a camera made it possible to detect an object in front of the robot and recognize if the object is an obstacle.
Analysis of the picture was divided into steps:
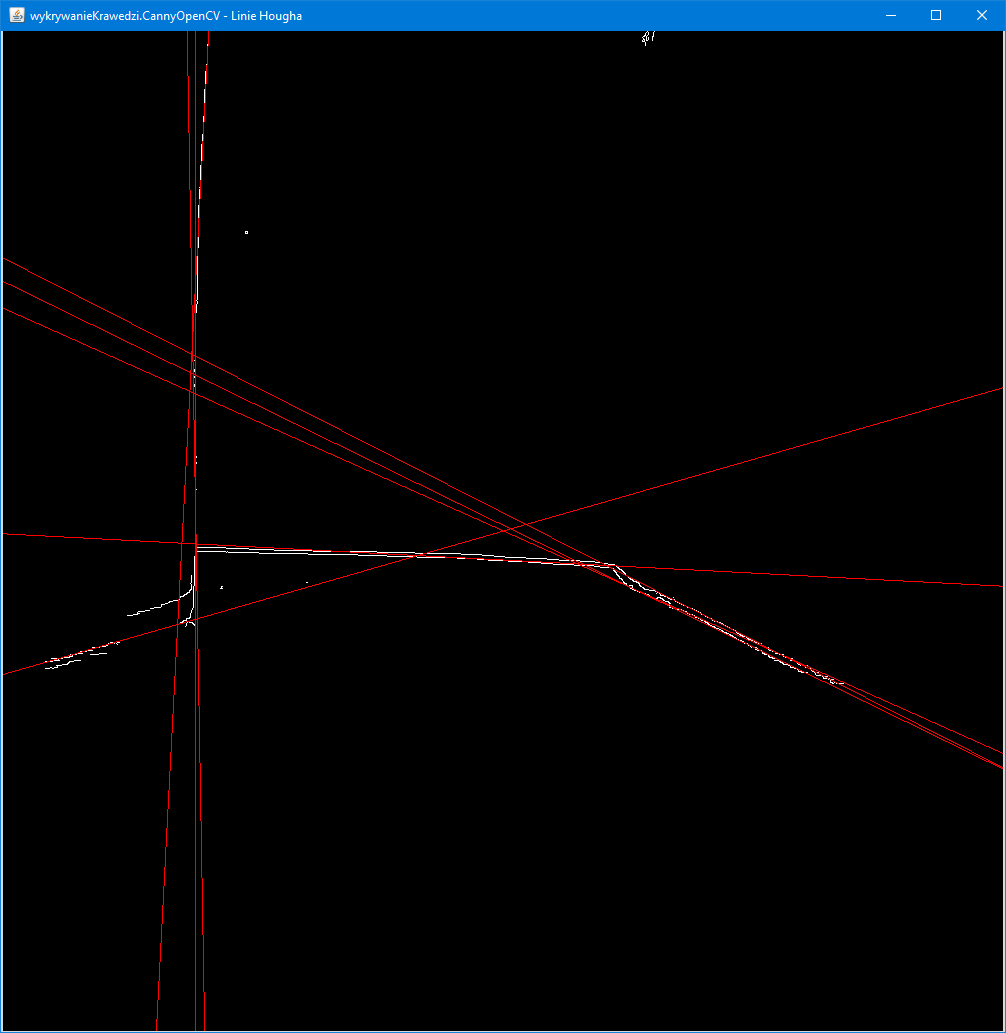
- edge detection (Canny’s method brought the best result)
- line detection based on recognized edges (Hough Transformation was used)
- line analysis regarding:
- objects – basic geometric figures
- obstacles – walls
The research was carried out in the enclosed environment – the special labyrinth.